Demonstrations
Video demonstrations from Cartio Robotics, showcasing the capabilities of our software platform. The solution is sensor-agnostic: every demonstration uses the same pipeline, regardless of the sensors in it.
-
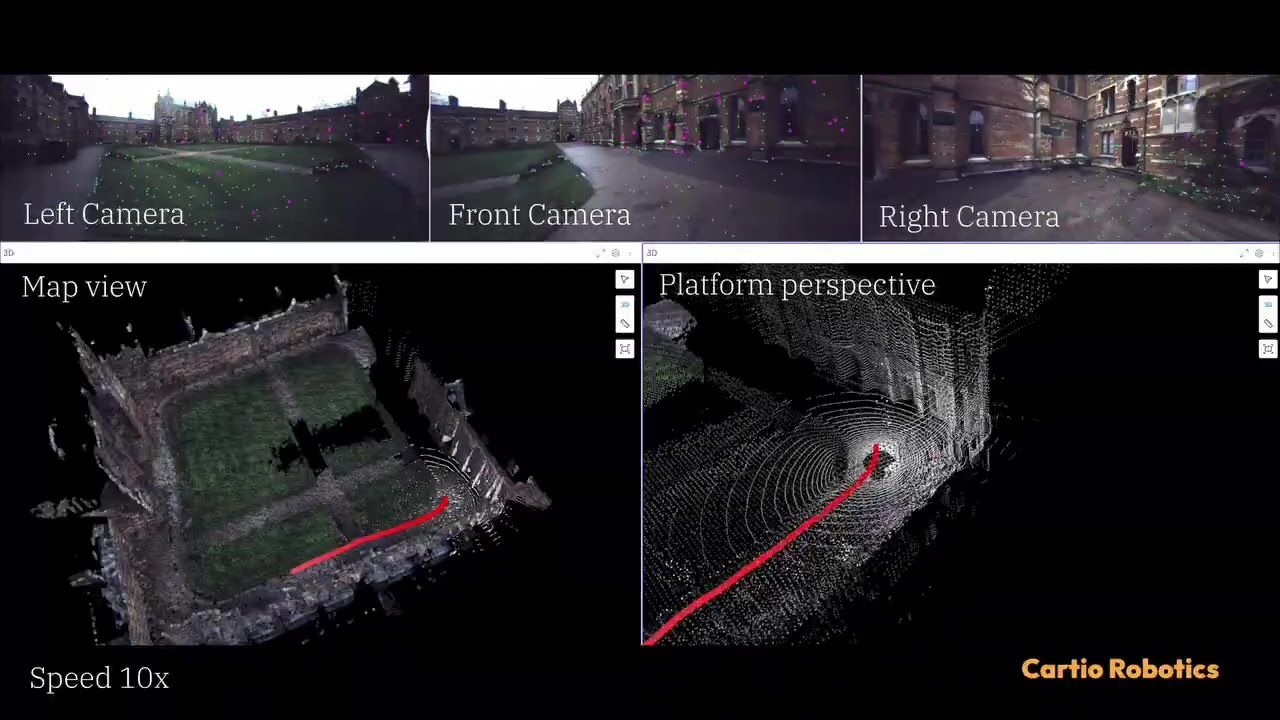 01
Active mapping, passive localization
We build the map with a lidar, cameras and an IMU. Then we localize in that map with the cameras only.
-
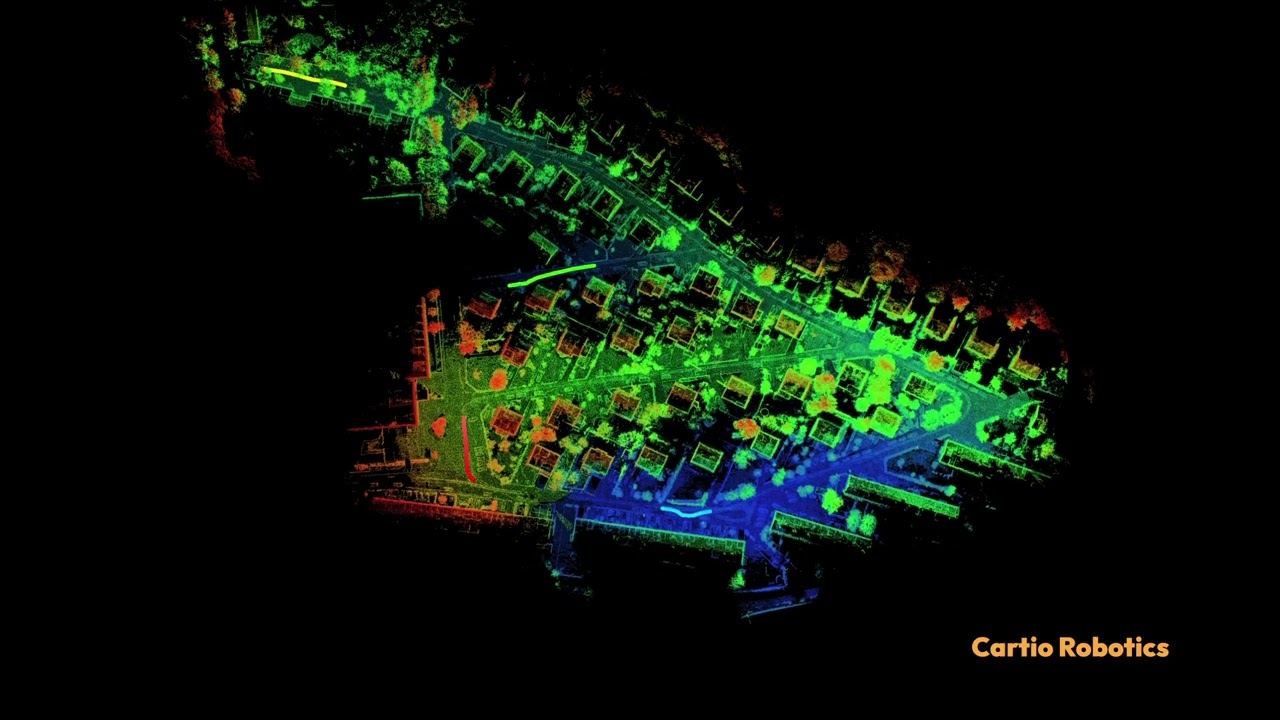 02
Collaborative SLAM
A fleet of autonomous vehicles builds SLAM maps together and shares them with each other. It works over multiple communication media.
-
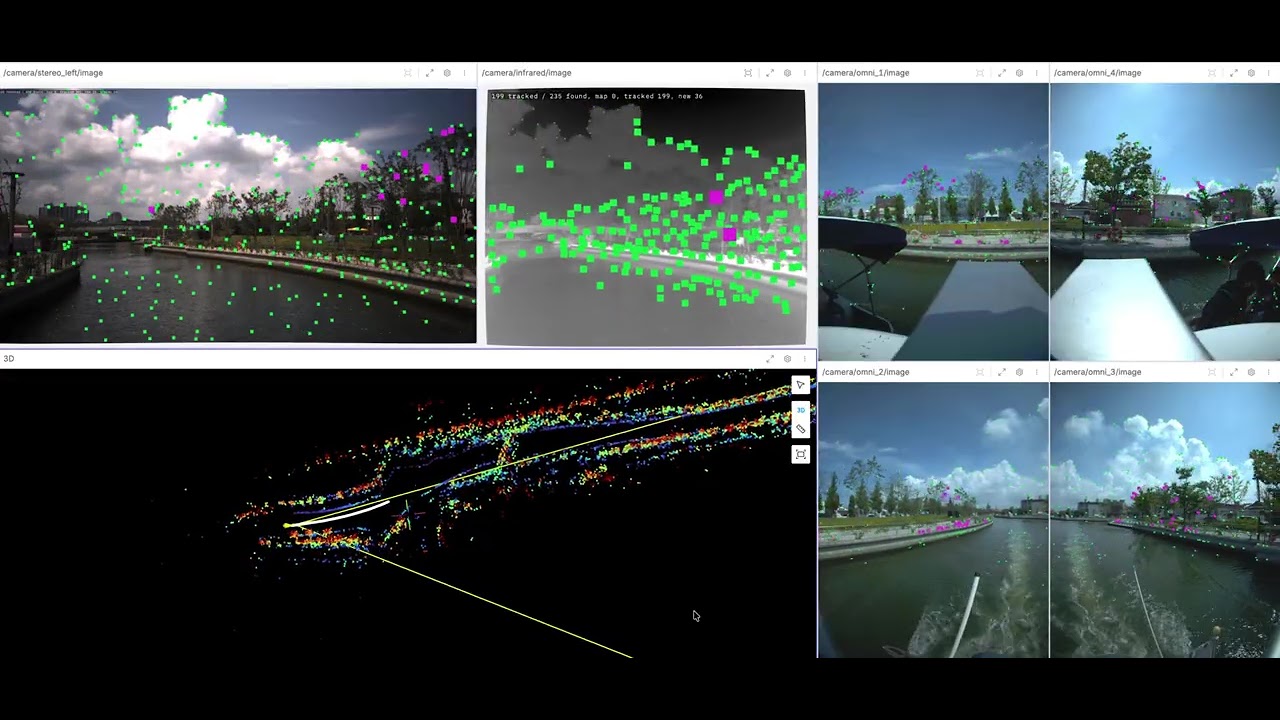 03
Visual-inertial odometry and mapping
Three cameras and an IMU are enough to find the motion of a boat and to map the area around it, by day or by night.